Mario Malizia

Mario Malizia
- I grew up in Cosenza, Italy, a beautiful city in the sunny South of Italy.
- I later moved to Milan where I pursued my BSc and MSc studies in Automation and Control Engineering at Politecnico di Milano.
- After my MSc, I worked as a Research Assistant at the Politecnico di Milano mOve Group, focusing on simulations and perception for autonomous driving applications in on-road and off-road environments.
- I am currently a Research Engineer at the Royal Military Academy (RMA) of Belgium, focusing on autonomous robotics applications within the Robotics and Autonomous Systems Group.
- In parallel, I have started a joint PhD with the KU Leuven ACRO research group, supervised by Prof. Eric Demeester and Prof. Nikolaos Tsiogkas on the KUL side and Prof. Rob Haelterman and Dr. Ken Hasselmann on the RMA side.
Research Interests
Autonomous Robotics
Field Robotics
Off-road Perception
Landmine Detection Occluded Object Detection Synthetic Data
Landmine Detection Occluded Object Detection Synthetic Data
Publications & Workshops
Towards replacing real images with synthetic data for surface landmine detection (2026)
IEEE SSRR
ConferenceOralProvisional
Paper — coming soonRepository
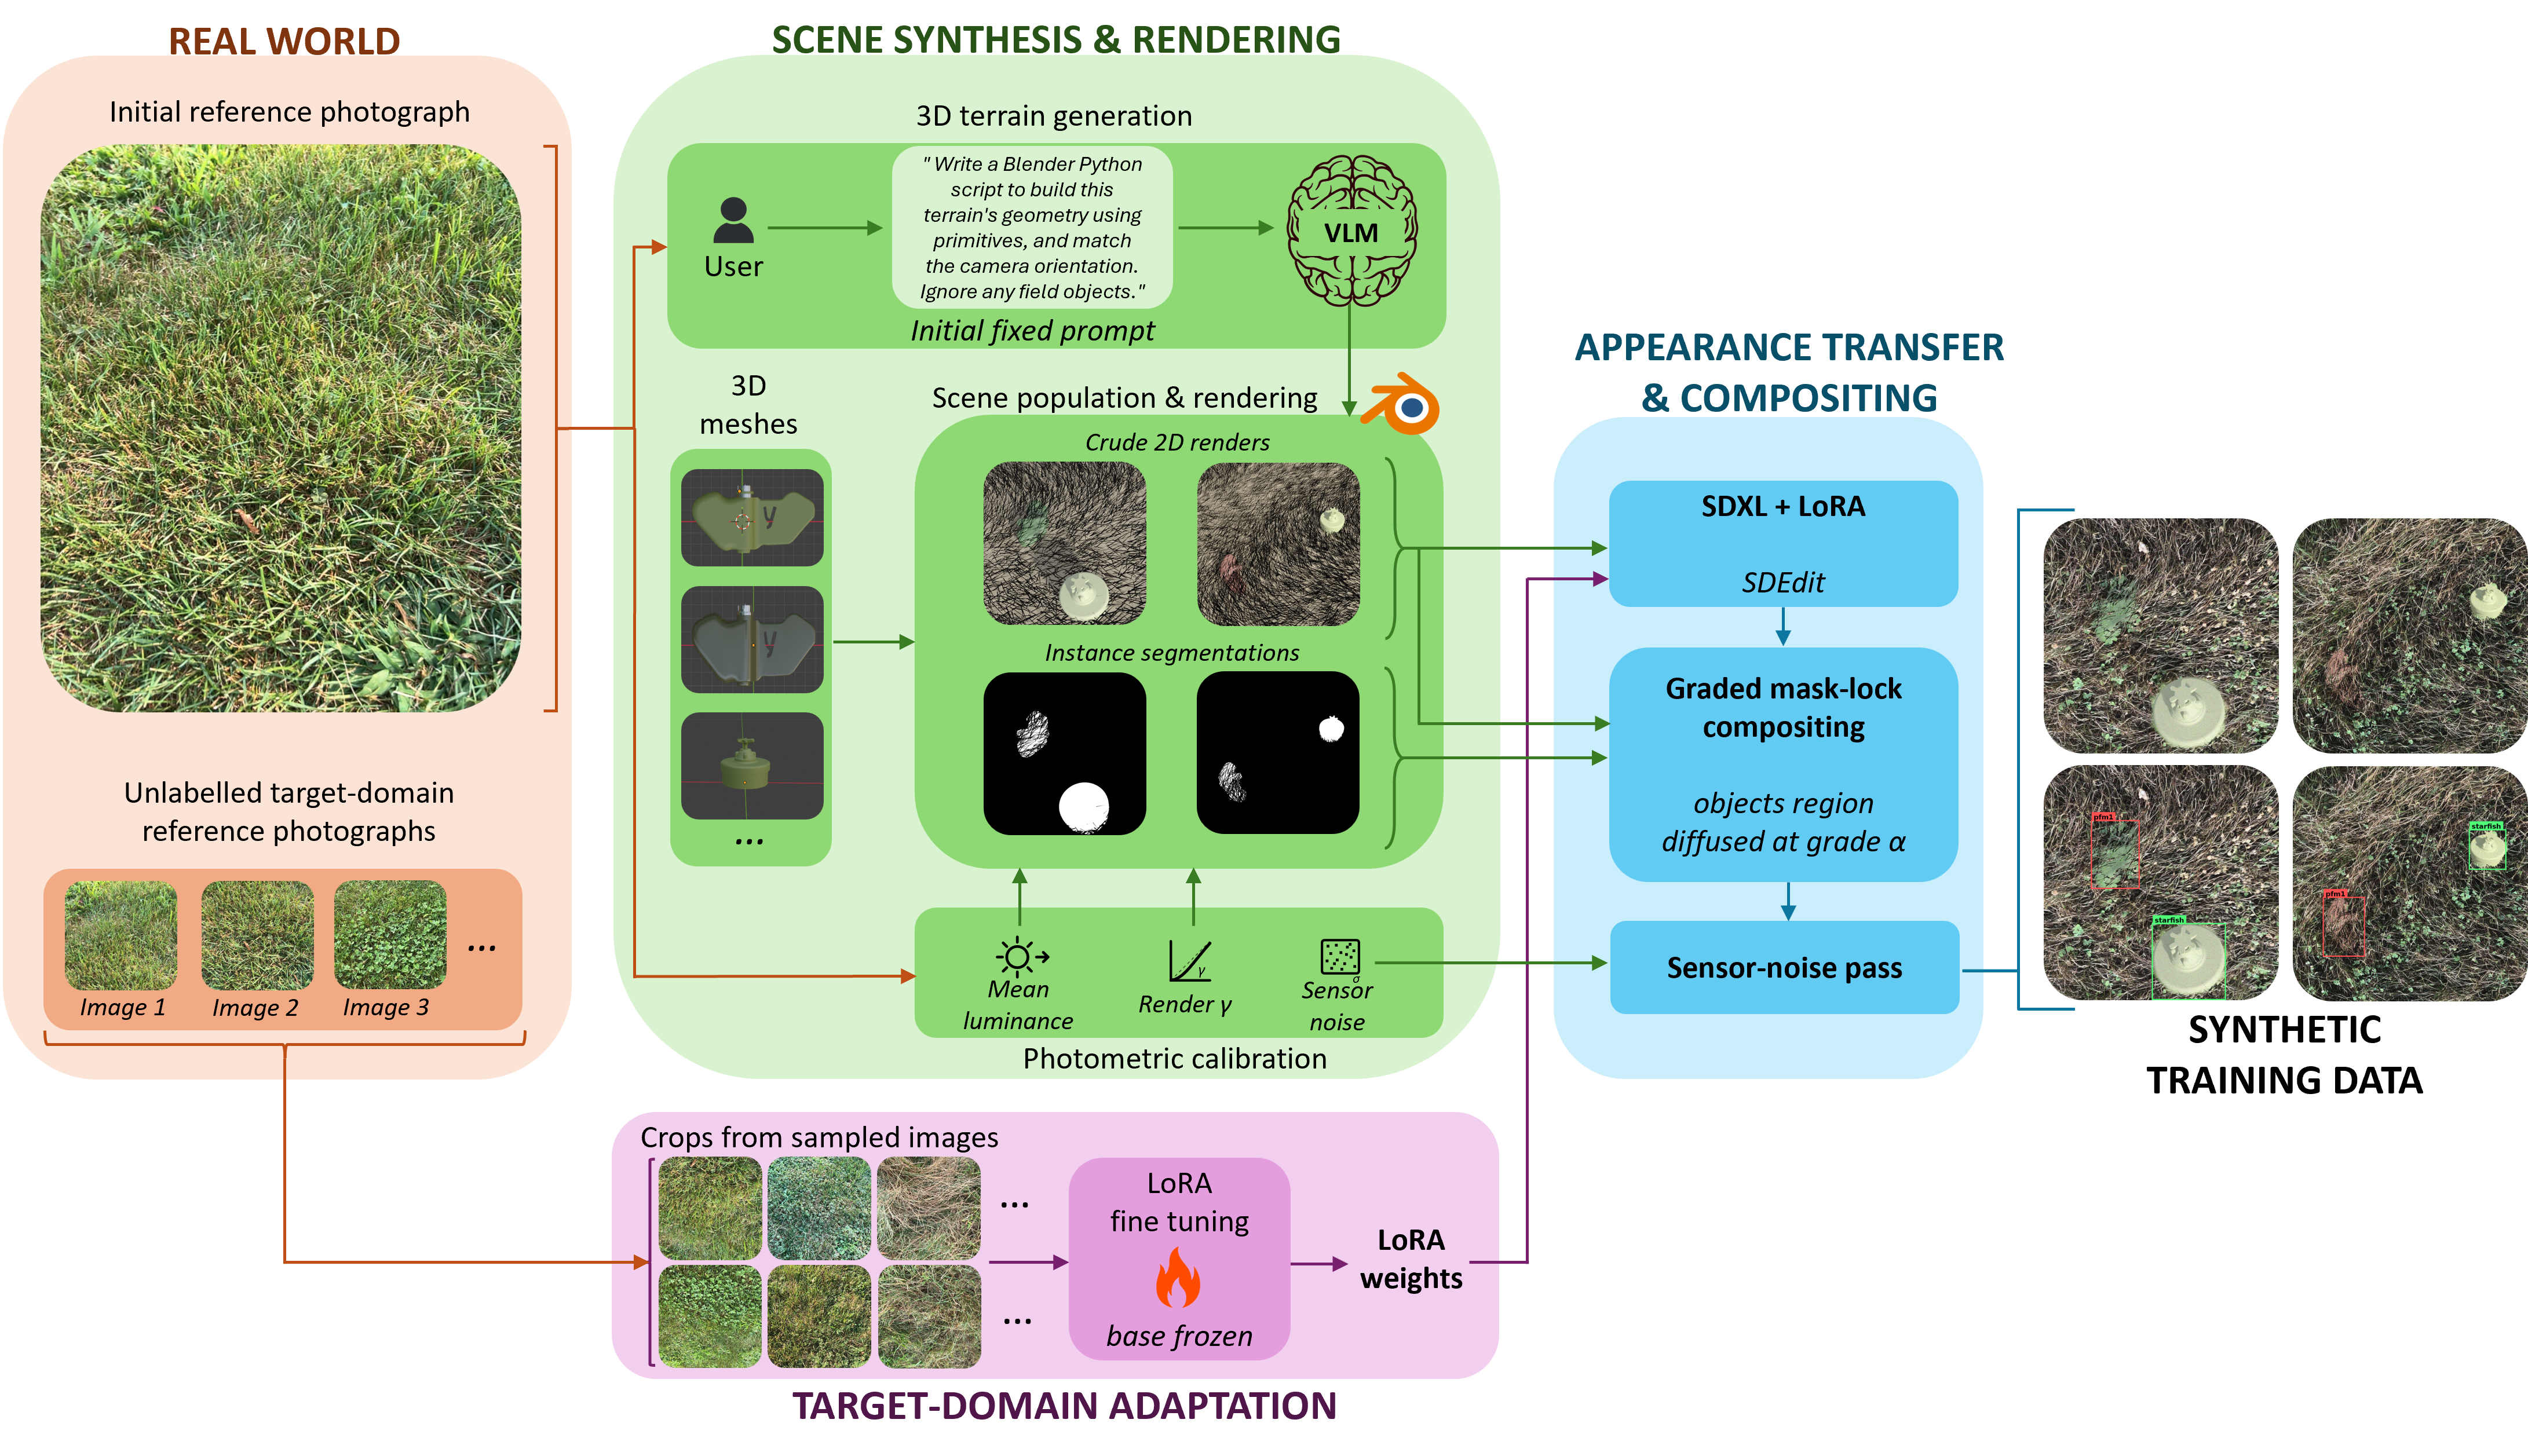
Diffuse the object, keep its label: curating detector training data from a few unlabeled photographs via VLM-built 3D vegetation scenes (2026)
ECCV · Curated Data for Efficient Learning (CDEL) Workshop
WorkshopOralPoster

MineInsight: a multi-sensor dataset for humanitarian demining robotics in off-road environments (2025)
IEEE RA-L
JournalOral @ IEEE ICRA

PFM-1 landmine detection in vegetation using thermal imaging with limited training data (2025)
IEEE ICCAS
ConferenceOral

HADRON: human-friendly control and artificial intelligence for military drone operations (2024)
IEEE RO-MAN · Variable Autonomy for Human-Robot Teaming Workshop
WorkshopPoster

A multi-robot system for the detection of explosive devices (2024)
IEEE ICRA · Field Robotics Workshop
WorkshopPoster